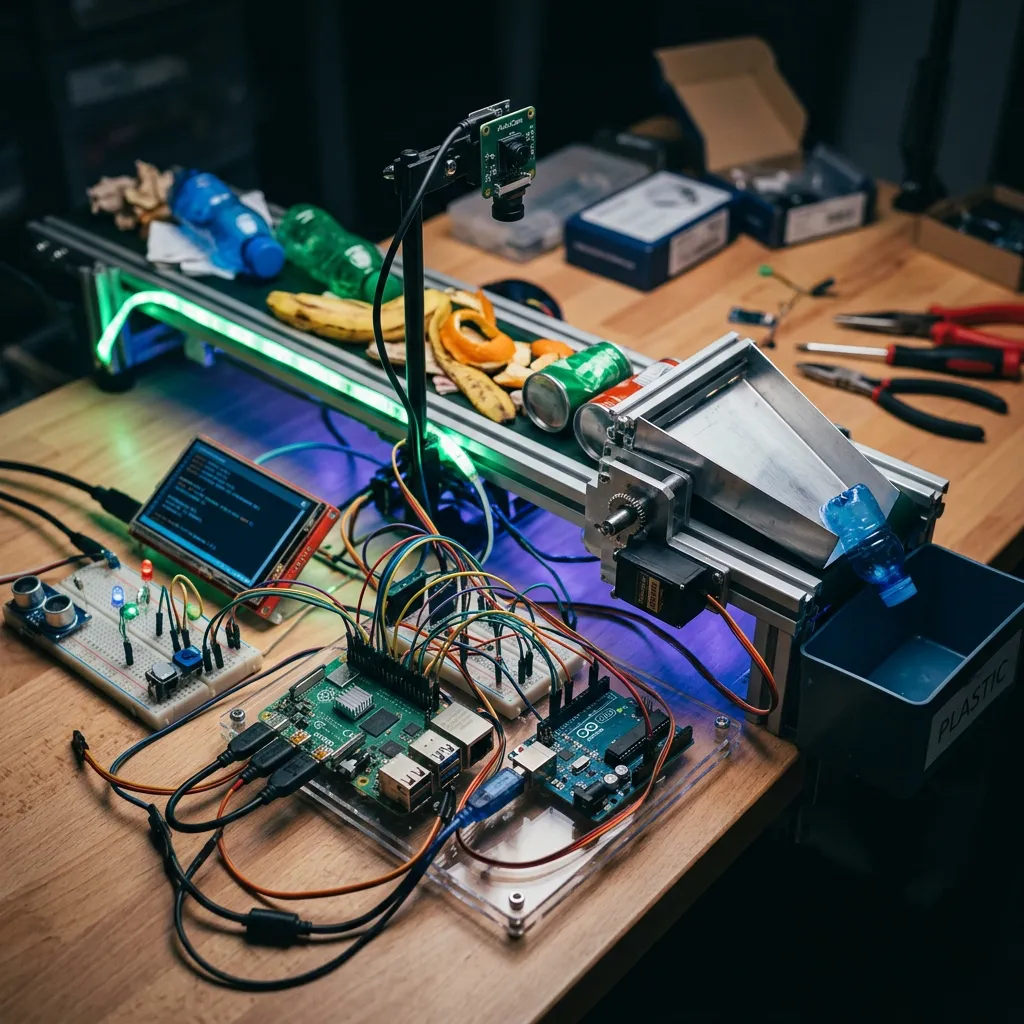
NeuraBin / GreenSort — Smart Waste Intelligence System
Conventional municipal waste bins rely only on fill-level monitoring, ignoring waste segregation, density anomalies, and hazardous decomposition gases like methane and ammonia.
My Role & Contribution
Co-Author & System Architect: Fine-tuned the 4-class ResNet classifier (90 mAP at 1.7s CPU latency), programmed UART communication between Raspberry Pi and Arduino Uno, and designed the classification-aware route optimization algorithm.
Proposed Solution
Designed and built an end-to-end prototype: when a citizen approaches, a PIR sensor signals the Arduino to open the lid and rotate the platform. An OV2640 camera captures an image; the Raspberry Pi executes our custom ResNet classifier to categorize waste into 4 classes. Sensor telemetry and classification tags stream via MQTT to Supabase, driving an administrative route optimization dashboard.
- Custom-trained ResNet model achieving 90 mAP on 4 waste classes at 1.7s edge inference latency on CPU
- Dual-microcontroller architecture: Arduino Uno handles real-time sensors & servos; Raspberry Pi runs AI & MQTT
- Multi-sensor hardware suite: HC-SR04 ultrasonic (fill level), load cell (density anomaly), MQ-135/MQ-2 (gas safety), TCRT5000 (PIR user presence)
- Cloud-connected telemetry via MQTT to Supabase PostgreSQL real-time database
- Greedy nearest-neighbour route optimization prioritizing bins with >80% fill or Hazardous waste flags
- Sub-₹5,000 total prototype build cost, demonstrating viable municipal economics
Architecture & Dataflow
Implementation Status & Roadmap
Implemented
- Four-class visual classifier: Biodegradable (91.2% mAP), Recyclable, Non-Recyclable (88.5% mAP), Hazardous
- Dual UART communication protocol between Arduino Uno and Raspberry Pi
- Lid opening (SG90 servo) and 90° platform rotation (stepper motor) disposal sequence
- VMC Web Dashboard with classification-driven route planning
- Passed 8/8 comprehensive prototype test cases
Planned Roadmap
- Battery-efficient sleep states with solar-harvesting power management
- On-device TensorRT / NPU acceleration for sub-500ms inference
- Mobile citizen reporting app with automatic geotagging validation
Engineering Trade-offs & Limitations
Rationale:Selected ResNet over MobileNet after initial tests showed MobileNet struggled with food-contaminated paper, whereas ResNet's residual skip connections resolved the ambiguity. We optimized the model for CPU execution, keeping inference under 1.7 seconds without requiring expensive edge GPU accelerators.
Results & Evaluation
Achieved 90 overall mAP on real in-bin waste conditions. All 8 hardware-software test scenarios passed (MAE 3.2% on ultrasonic, 2.8% on weight). Co-authored research paper written for SustainX 2026.
Academic Publication
GreenSort: An Integrated IoT and Deep Learning System for Real-Time Municipal Solid Waste Segregation, Hazard Detection, and Route Optimization
Municipal solid waste (MSW) generation is projected to reach 3.4 billion tonnes annually by 2050, with Indian cities disproportionately affected due to rapid urbanization. Existing smart bins focus almost exclusively on fill-level monitoring, leaving waste classification, weight-based density anomaly detection, and hazardous gas monitoring largely unaddressed. This paper presents GreenSort, a prototype Smart Waste Management System (SWMS) for municipal deployment. A multi-sensor Arduino Uno feeds data to a Raspberry Pi running a custom-trained ResNet classifier fine-tuned via transfer learning on a four-class dataset, achieving 90 mAP at 1.7s edge inference latency. Sensor telemetry and classification outputs transmit via MQTT to a Supabase backend, powering dynamic route optimization. Total prototype cost: ~₹5,000.